Next-Gen Hydraulics Without Fluids
Designed high-force, long-stroke electromechanical linear actuators with Oshkosh that can fully replace hydraulics, as part of their effort to electrify their entire fleet.
Tools: CAD, CAM, CNC, DFM, Stress analysis, Market research, Customer value chain
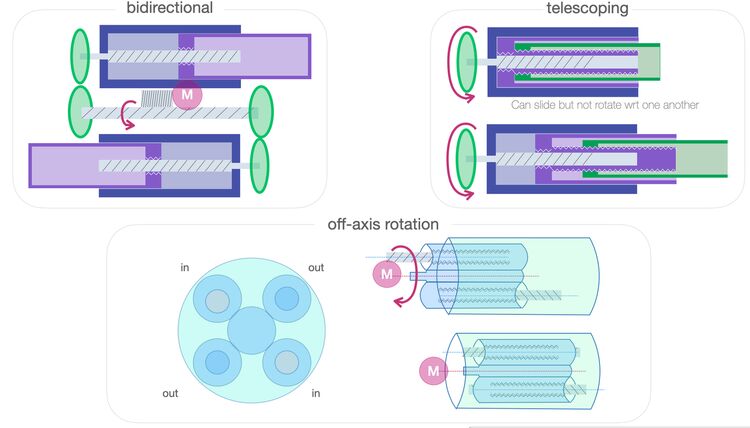
Worked on a senior 4-member capstone team in close collaboration with Oshkosh, designing next-generation high-force, long-stroke electromechanical linear actuators that can fully replace hydraulics in Oshkosh's effort to electrify their entire fleet.
This project was done as part of 2.76 Global Design under Prof. Amos Winter at MIT.
Key challenges
- Large collapsed and extended lengths (7 ft collapsed, 3× extension)
- High force application
- High efficiency and reliability requirements
After initial market research, and with the help of the team and our advisors, I came up with several concepts that could address these challenges.
Scale prototype
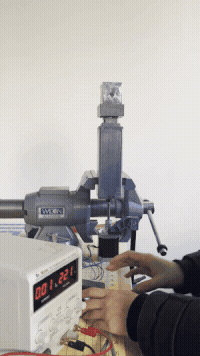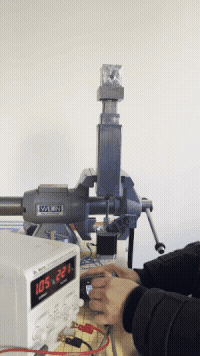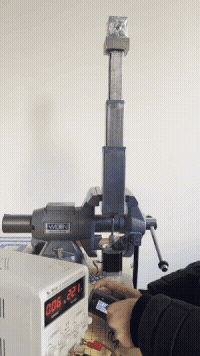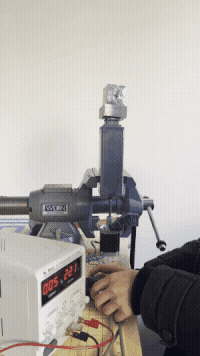
Lifting a 2 kg load up and down in real time.
After concept down-selection, a 1/14 scale prototype was designed and manufactured.
- The first prototype was 3D printed to finalize the mechanism design and assembly.
- The second prototype was custom-made from steel to match the full-scale material selection. Testing confirmed the scaled-down prototype hits the target speed and load, making the selected design plausible.
The prototype also highlighted challenges that need to be addressed to guarantee the success of the full-scale version.
Publication and patent
- "Proposed Design for Electromechanical Telescoping Actuator to Replace Hydraulics in Extreme High Force and Long Stroke Applications," ASME IDETC-2023 Conference
- Patent pending (GC Ref. No. MIT-250)