Automated Nerf Turret
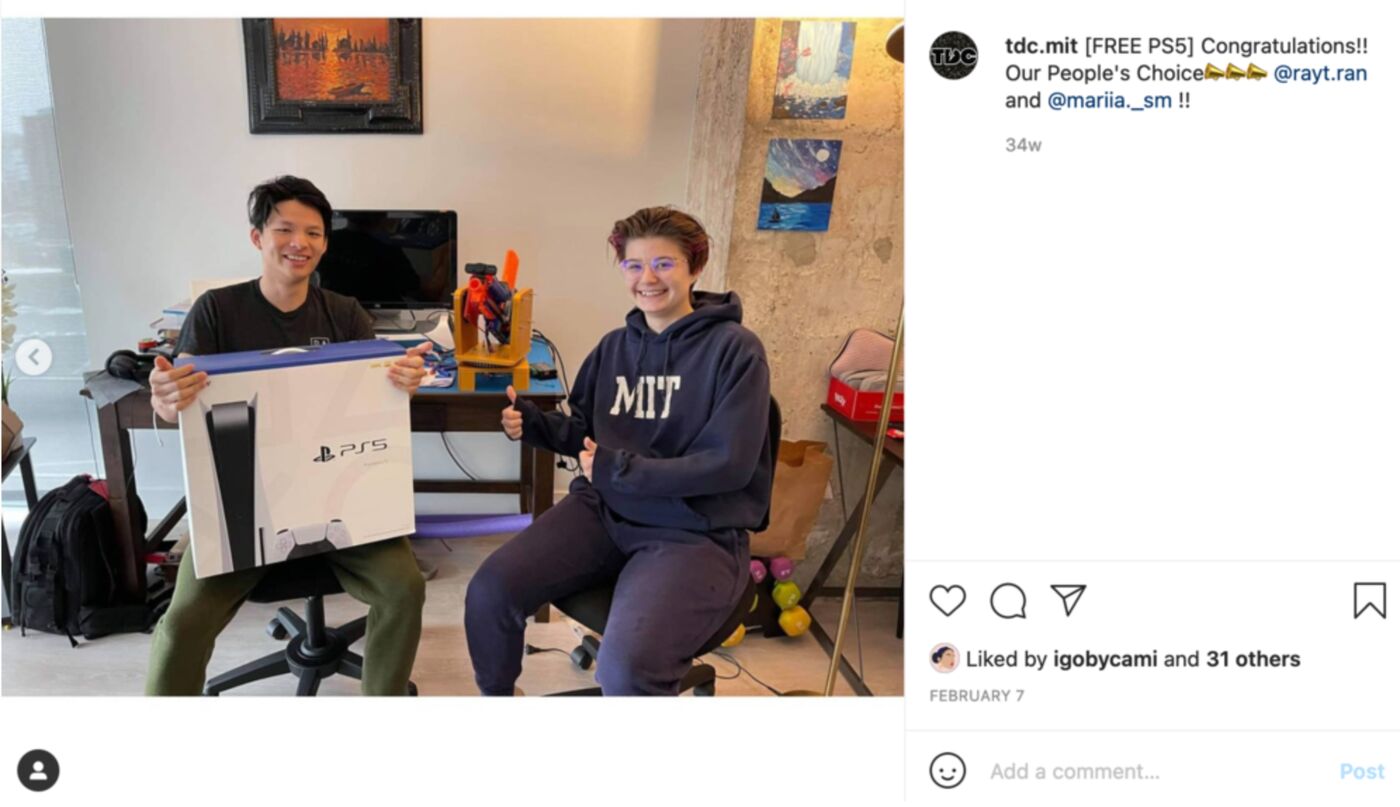
A 2-DOF motorized turret that follows and hits a person walking around the room. Won 1st place (and a PS5) at a TDC hackathon.
Tools: CAD, 3D printing, FEA, Electronics, Motors
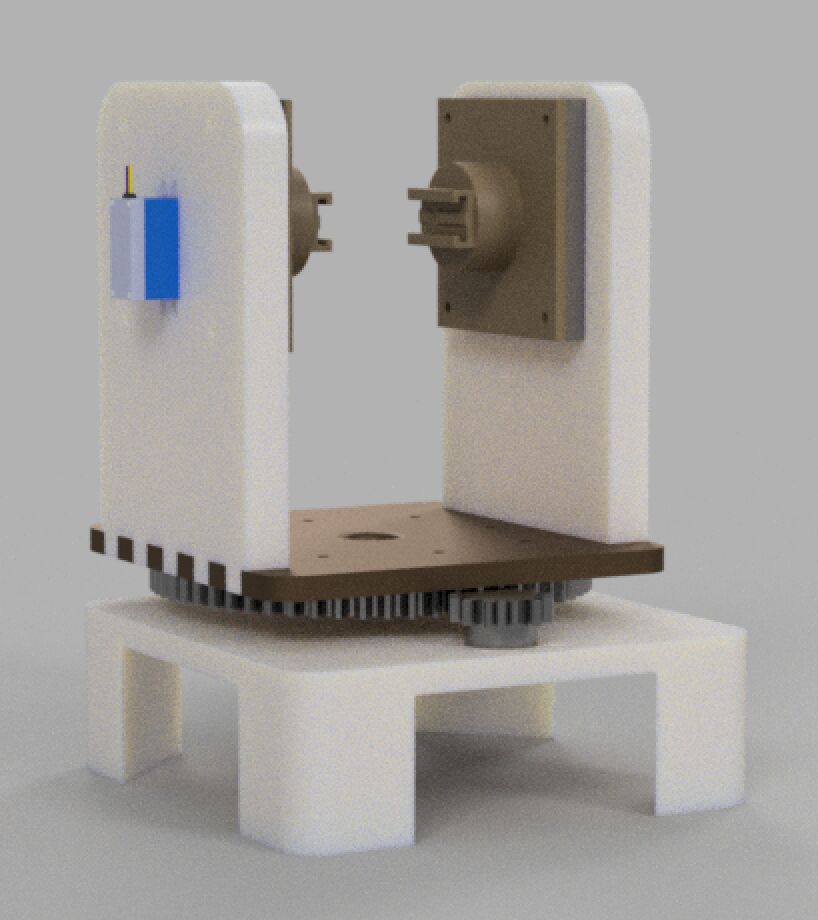
At the end of the covid semester (Fall 2020), I broke both bones in my left leg and was bedridden/house-bound for the holidays. I was a fresh sophomore just starting to develop my fundamentals of mechanical design, and I was bored. Below is a short summary of a fun project that my roommate and I worked on while I was recovering from a broken ankle in the middle of Boston winter during covid.
====
I designed a 2 degree-of-freedom motorized mount for a Nerf gun, creating a turret able to follow and hit a person walking around the room. My roommate handled the software and I handled the electromechanical parts. I built it to pass the time while stuck at home with a broken ankle, and we won a PS5 for 1st place at a TDC hackathon.
Process and challenges
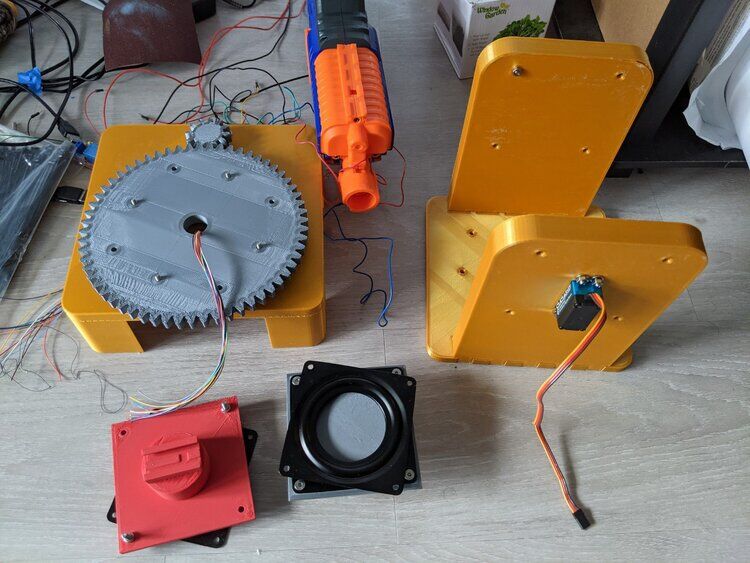
I designed the support and rotation mechanism for the Nerf gun. The mount was originally one piece, but it didn't fit on the available 3D printer, so I split it in two and oriented the parts and joints so the printed layers reinforce them. That version outperformed the original plan.
To let the turret spin more than 360° without tangling the wires, I added an electrical slip ring.
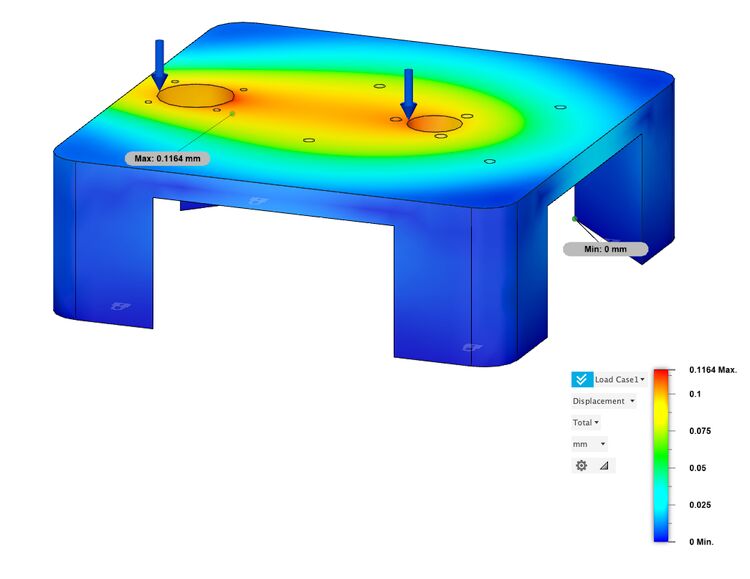
A displacement simulation was used to minimize deflection and material in the base, and to check that PLA (the material on hand) would be enough.
Results
I learned a lot about computer vision and motor control. Working with an electrical and computer engineer taught me the wiring and software constraints to keep in mind when designing electromechanical systems.
We also made this beautiful cinematic trailed of Samantha, the Nerf gun turret, in action. It was genuinely hard to dodge!
https://drive.google.com/file/d/1Fv07Psk1uBN22bb-PQk0JnQKyeKQb4dk/view?usp=sharing